1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
35
36
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
69
70
71
72
73
74
75
76
77
78
79
80
81
82
83
84
85
86
87
88
89
90
91
92
93
94
95
96
97
98
99
100
101
102
103
104
105
106
107
108
109
110
111
112
113
114
115
116
117
118
119
120
121
122
123
124
| import numpy as np
import matplotlib.pyplot as plt
from scipy.optimize import linprog
from matplotlib.patches import Polygon
def plot_constraints(x_range, constraints, ax=None):
"""Plot the constraints and feasible region"""
if ax is None:
ax = plt.gca()
x = np.linspace(x_range[0], x_range[1], 1000)
colors = ['b', 'g', 'r', 'c', 'm']
for i, (a, b, c) in enumerate(constraints):
if b != 0:
y = (c - a*x) / b
ax.plot(x, y, f'{colors[i%len(colors)]}--', label=f'Constraint {i+1}')
else:
ax.axvline(x=c/a, color=colors[i%len(colors)], linestyle='--',
label=f'Constraint {i+1}')
vertices = []
n = len(constraints)
for i in range(n):
for j in range(i+1, n):
a1, b1, c1 = constraints[i]
a2, b2, c2 = constraints[j]
A = np.array([[a1, b1], [a2, b2]])
b = np.array([c1, c2])
try:
x, y = np.linalg.solve(A, b)
if all((a*x + b*y <= c) for a, b, c in constraints):
vertices.append([x, y])
except np.linalg.LinAlgError:
continue
for x_val in x_range:
for (a, b, c) in constraints:
if b != 0:
y = (c - a*x_val) / b
if all((a2*x_val + b2*y <= c2) for a2, b2, c2 in constraints):
vertices.append([x_val, y])
if vertices:
vertices = np.array(vertices)
hull = [vertices[0]]
current = vertices[0]
vertices = vertices[vertices[:, 0].argsort()]
while len(hull) < len(vertices):
distances = np.linalg.norm(vertices - current, axis=1)
next_point = vertices[np.argmax(distances)]
if not np.array_equal(next_point, hull[0]):
hull.append(next_point)
current = next_point
else:
break
hull = np.array(hull)
ax.add_patch(Polygon(hull, alpha=0.3, color='gray', label='Feasible Region'))
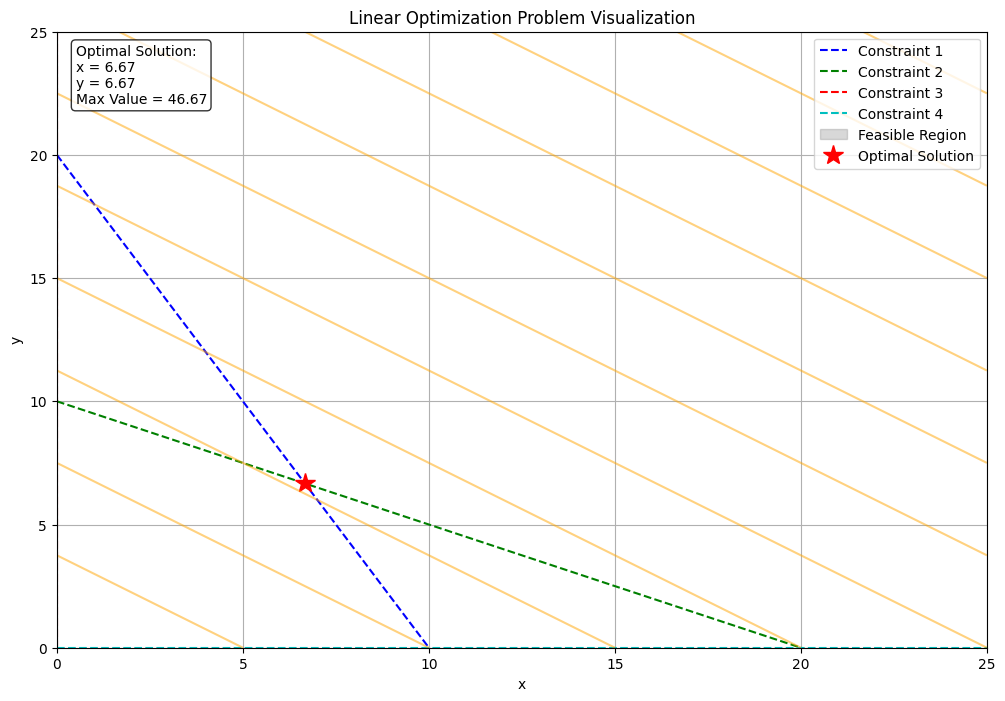
"""
Maximize: z = 3x + 4y
Subject to:
    2x + y ≤ 20
    x + 2y ≤ 20
    x, y ≥ 0
"""
c = [-3, -4]
A = [[2, 1],
[1, 2]]
b = [20, 20]
x_bounds = (0, None)
y_bounds = (0, None)
result = linprog(c, A_ub=A, b_ub=b, bounds=[x_bounds, y_bounds], method='simplex')
plt.figure(figsize=(12, 8))
constraints = [
[2, 1, 20],
[1, 2, 20],
[1, 0, 0],
[0, 1, 0]
]
plot_constraints([0, 25], constraints)
x_opt, y_opt = result.x
plt.plot(x_opt, y_opt, 'r*', markersize=15, label='Optimal Solution')
x = np.linspace(0, 25, 100)
y = np.linspace(0, 25, 100)
X, Y = np.meshgrid(x, y)
Z = 3*X + 4*Y
plt.contour(X, Y, Z, levels=15, alpha=0.5, colors='orange')
plt.grid(True)
plt.xlabel('x')
plt.ylabel('y')
plt.title('Linear Optimization Problem Visualization')
plt.legend()
plt.axis([0, 25, 0, 25])
optimal_value = -result.fun
plt.text(0.02, 0.98, f'Optimal Solution:\nx = {x_opt:.2f}\ny = {y_opt:.2f}\nMax Value = {optimal_value:.2f}',
transform=plt.gca().transAxes, verticalalignment='top',
bbox=dict(boxstyle='round', facecolor='white', alpha=0.8))
plt.show()
|